


When Determine introduced earlier this yr that it was engaged on a basic goal humanoid robotic, our pleasure was tempered considerably by the truth that the corporate didn’t have a lot to indicate in addition to renders of the robotic that it hoped to ultimately construct. Determine had a slick trying imaginative and prescient, however with out something to again it up (in addition to a world-class robotics workforce, in fact), it was unclear how briskly they’d be capable of progress.
Because it seems, they’ve progressed fairly darn quick, and at the moment Determine is unveiling its Determine 01 robotic, which has gone from nothing in any respect to dynamic strolling in beneath a yr.
A few issues to notice in regards to the video, when you tear your eyes away from that shiny steel pores and skin and the large battery backpack: first, the robotic is strolling dynamically with no tether and there aren’t any nervous-looking roboticists inside straightforward grabbing distance. Spectacular! Dynamic strolling signifies that there are factors throughout the robotic’s gait cycle the place abruptly stopping would trigger the robotic to fall over, because it’s relying on momentum to maintain itself in movement. It’s the form of strolling that people do, and is considerably harder than a extra conventional “robotic” stroll, through which a robotic makes positive that its middle of mass is at all times safely positioned above a strong floor contact. Dynamic strolling can also be the place these light arm swings come from—they’re serving to hold the robotic’s movement easy and balanced, once more in a human-like means.
The second factor that stands out is how skinny (and glossy!) this robotic is, particularly in case you can look previous the cable routing. Determine had initially proven renderings of a robotic with the shape issue of a slim human, however there’s normally a fairly large distinction between an preliminary fancy render and actual {hardware} that reveals up months later. It now seems like Determine truly has a shot at maintaining to that slim design, which has a number of advantages—there are human-robot interplay issues, the place a smaller type issue is more likely to be much less intimidating, however extra importantly, the mass you save by slimming down as a lot as attainable results in a robotic that’s extra environment friendly, cheaper, and safer.
Clearly, there’s much more occurring right here than Determine may squeeze into is press launch, so for extra particulars, we spoke with Jenna Reher, a Senior Robotics/AI Engineer at Determine, and Jerry Pratt, Determine’s CTO.
What was the method like so that you can train this robotic learn how to stroll? How tough was it to do this in a yr?
Jenna Reher: We’ve been actually targeted on ensuring that we’re validating numerous the {hardware} because it’s constructed. With the robotic that’s proven within the video, earlier this yr it was simply the pelvis bolted onto a check fixture. Then we added the backbone joints and all of the joints linked to that pelvis, and actually constructed the robotic out from that pelvis. We added the legs and had these swinging within the air, after which constructed up the torso on prime of that. At every of these levels, we have been ensuring to have a very good course of for validating that these low stage items of this total system have been rather well tuned in. I believe that after you get to one thing as advanced as a complete humanoid, all that validation actually saves you numerous time on the opposite finish, since you may have much more confidence within the decrease stage techniques as you begin engaged on greater stage behaviors like locomotion
We even have lots of people on the firm which have expertise on prior legged robotic platforms, so there’s a nicely of data that we will draw from there. And there’s a big pool of literature that’s been printed by individuals within the locomotion group that roboticists can now pull from. With our locomotion controller, it’s not like we’re attempting to reinvent secure locomotion, so having the ability to implement issues that we all know already work is an enormous assist.
Jerry Pratt: The strolling algorithm we’re utilizing has numerous similarities to those that have been developed throughout the DARPA Robotics Problem. We’re doing numerous machine studying on the notion aspect, however we’re probably not doing any machine studying for management proper now. For the strolling algorithm, it’s just about robotics controllers 101.
And Jenna talked about the step-by-step {hardware} bring-up. Whereas that’s occurring, we’re doing numerous growth on the controller in simulation to get to the purpose the place the robotic is strolling in simulation fairly nicely, which signifies that we have now a very good likelihood of the controller engaged on the actual robotic as soon as it comes on-line. I believe as an organization, we’ve carried out a very good job coordinating all of the items, and numerous that has come from having individuals with the expertise of getting carried out this a number of instances earlier than.
Extra broadly, eight years after the DARPA Robotics Problem, how onerous is it to get a human-sized bipedal robotic to stroll?
Pratt: Theoretically, we perceive strolling fairly nicely now. There are numerous totally different easy fashions, totally different toolboxes which are accessible, and a few dozen totally different approaches which you could take. A number of it is dependent upon having good {hardware}—it may be actually tough in case you don’t have that. However for okay-ish strolling on flat floor, it’s develop into simpler and simpler now with the entire prior work that’s been carried out.
There are nonetheless numerous challenges for strolling naturally, although. We actually need to get to the purpose the place our robotic seems like a human when it walks. There are some robots which have gotten shut, however none that I’d say have handed the Turing check for strolling, the place in case you checked out a silhouette of it, you’d suppose it was a human. Though, there’s not a very good enterprise case for doing that, besides that it needs to be extra environment friendly.
Jenna: Strolling is changing into increasingly more understood, and likewise accessible to roboticists if in case you have the {hardware} for it, however there are nonetheless numerous challenges to have the ability to stroll whereas doing one thing helpful on the identical time—interacting along with your atmosphere whereas transferring, manipulating issues whereas transferring—these are nonetheless difficult issues.
What are some vital issues to search for if you see a bipedal robotic stroll to get a way of how succesful it could be?
Reher: I believe we as people have fairly good instinct for judging how nicely one thing is locomoting—we’re form of hardwired to do it. So in case you see buzzing oscillations, or a really stiff higher physique, these could also be indications {that a} robotic’s low-level controls are usually not fairly there. A number of success in bipedal strolling comes down to creating positive {that a} very advanced techniques engineering structure is all enjoying good collectively.
Pratt: There have been some latest efforts to provide you with efficiency metrics for strolling. Some are form of apparent, like strolling velocity. Some are tougher to measure, like robustness to disturbances, as a result of it issues what section of gait the robotic is at when it will get pushed—in case you push it at simply the best time, it’s a lot tougher for it to get better. However I believe the individual pushing the robotic check is a reasonably good one. Whereas we haven’t carried out pushes but, we most likely will in an upcoming video.
How vital is it to your robotic to have the ability to fall safely, and at what level do you begin designing for that?
Pratt: I believe it’s vital to fall safely, to outlive a fall, and be capable of get again up. Folks fall— not fairly often, however they do— they usually get again up. And there shall be instances in nearly any utility the place the robotic falls for one cause or one other and we’re going to have to only settle for that. I typically inform individuals engaged on humanoids to construct in a fall conduct. If the robotic’s not falling, make it fall! As a result of in case you’re attempting to make the robotic in order that it could possibly by no means fall, it’s simply too onerous of an issue, and it’s going to fall anyway, after which it’ll be harmful.
I believe falling could be carried out safely. So long as computer systems are nonetheless answerable for the {hardware}, you are able to do very swish, judo-style falls. It’s best to be capable of detect the place individuals are if you’re falling, and fall away from them. So, I believe we will make these robots comparatively secure. The toughest a part of falling, I believe, is defending your palms so that they don’t break as you’re falling. However it’s positively not an insurmountable downside.
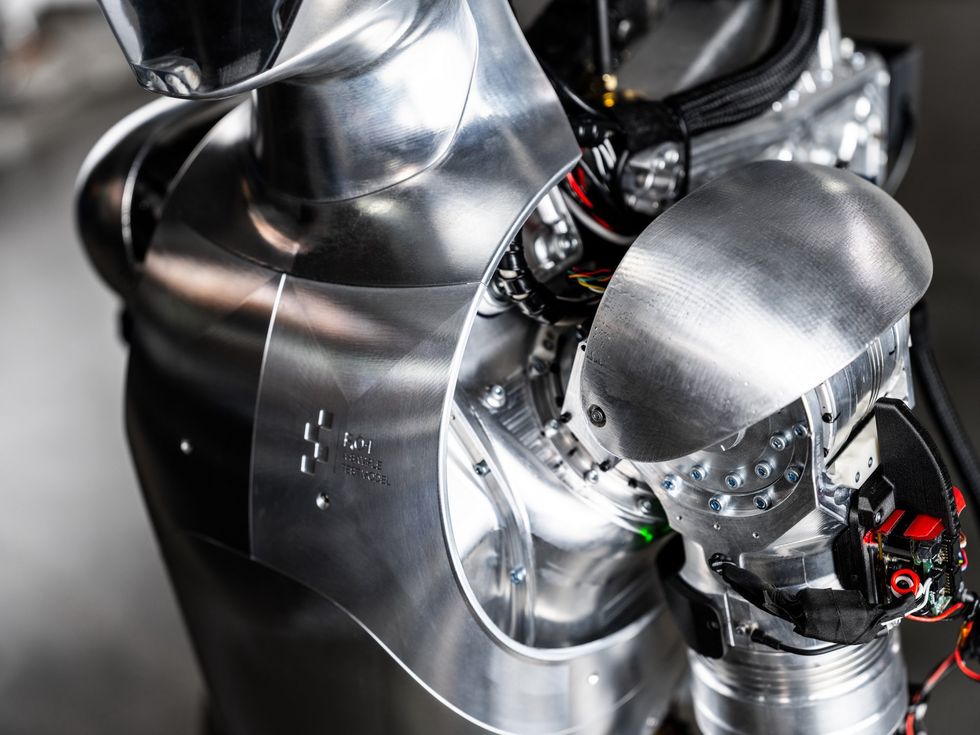 Industrial design is a spotlight of Determine.Determine
You’ve a really slim and glossy robotic. Did the design require any engineering compromises?
Pratt: It’s truly a very wholesome collaboration. We’re attempting to suit inside a medium-size feminine physique form, and so the commercial design workforce will make these actually smooth trying robotic silhouettes and say, “okay mechanical workforce, every little thing wants to slot in there.” And the mechanical workforce shall be like, “we will’t match that motor in, we’d like a pair extra millimeters.” It’s form of enjoyable watching the discussions, and generally there shall be arguments and stuff, nevertheless it nearly at all times results in a greater design. Even when it’s just because it causes us to take a look at the issue a few additional instances.
Reher: From my perspective, the form of interplay with the mechanical engineers that led to the robotic that we have now now has been very useful for the controls aspect. We’ve got a sleeker design with decrease inertia legs, which signifies that we’re not attempting to maneuver numerous mass round. That finally ends up serving to us down the road for designing management algorithms that we will execute on the {hardware}.
Pratt: That’s proper. And maintaining the legs slim lets you do issues like crossover steps—you get extra vary of movement since you don’t have elements of the robotic bumping into one another. Self-collisions are one thing that you just at all times have to fret about with a robotic, so in case your robotic has fewer protruding cables or bumps, it’s fairly vital.
Your CEO posted an image of some compact customized actuators that your robotic is utilizing. Do you are feeling like your actuator design (or one thing else) offers your robotic some form of secret sauce that may assist or not it’s profitable?
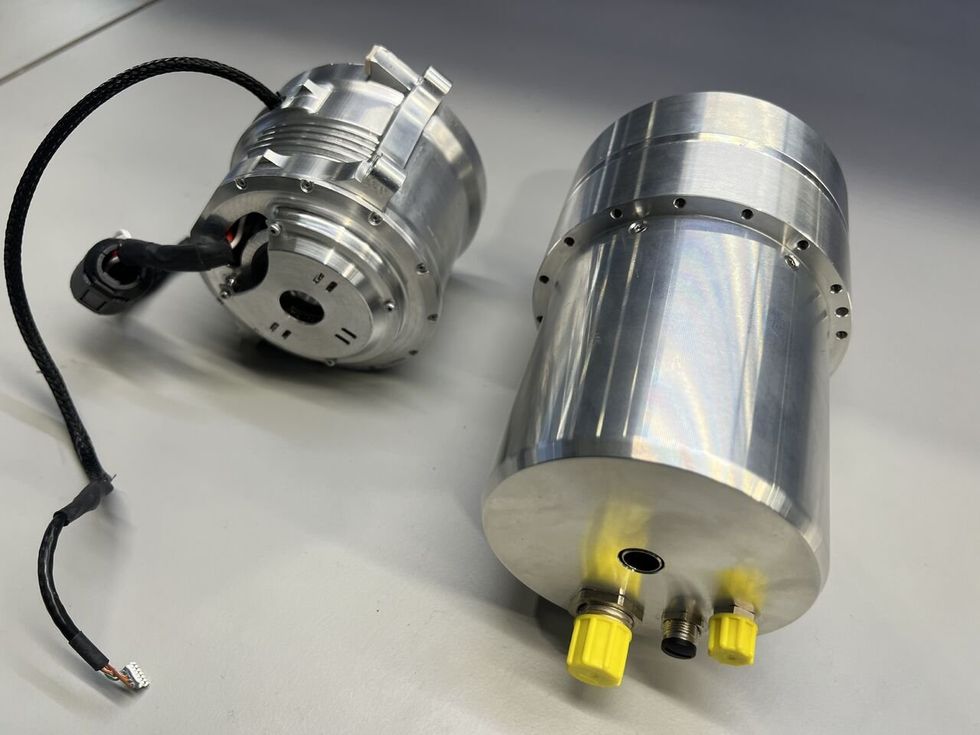 Determine’s customized actuator (left) vs. off-the-shelf actuator (proper) with equal torque.Determine
Pratt: At this level, it’s largely actually wonderful engineering and software program growth and tremendous proficient individuals. About half of our workforce have labored on humanoids earlier than, and half of our workforce have labored in some associated discipline. That’s vital— issues like, making batteries for vehicles, making electrical motors for vehicles, software program and administration techniques for electrical airplanes. There are some things we’ve realized alongside the way in which that we hadn’t realized earlier than. Possibly they’re not tremendous secret issues that different individuals don’t know, however there’s a handful of tips that we’ve picked up from bashing our heads towards some downside again and again. However there’s not numerous new know-how going into the robotic, let’s put it that means.
Are there alternatives within the humanoid robotic house for somebody to develop a brand new know-how that will considerably change the trade?
Pratt: I believe attending to no matter it takes to open up new utility areas, and do it comparatively shortly. We’re serious about issues like utilizing massive language fashions to plan basic goal duties, however they’re not fairly there but. A number of the examples that you just see are on the research-y stage the place they could work till you alter up what’s occurring—it’s not strong. But when somebody cracks that open, that’s an enormous benefit.
After which hand designs. If someone can provide you with a brilliant strong massive diploma of freedom hand that has power sensing and tactile sensing on it, that will be large too.
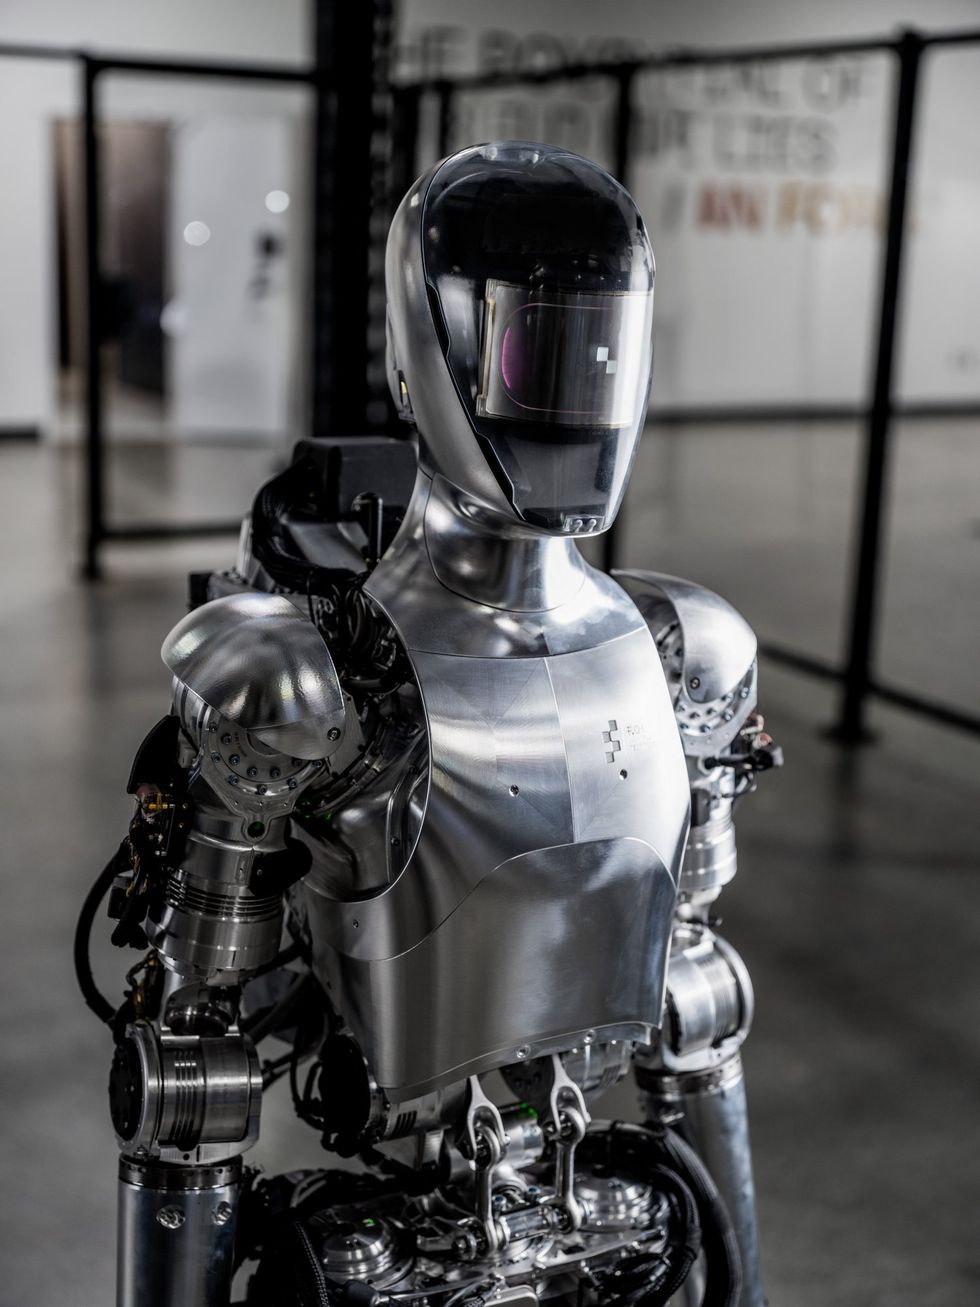 The robotic is designed to suit inside a medium-size feminine physique form.Determine
It is a lot of progress from Determine in a really quick time, however they’re definitely not alone of their purpose of growing a business bipedal robotic, and relative to different firms who’ve had operational {hardware} for longer, Determine could have some catching as much as do. Or they could not—till we begin seeing robots doing sensible duties outdoors of fastidiously managed environments, it’s onerous to know for positive.
From Your Web site Articles
Associated Articles Across the Internet

